
 3:43
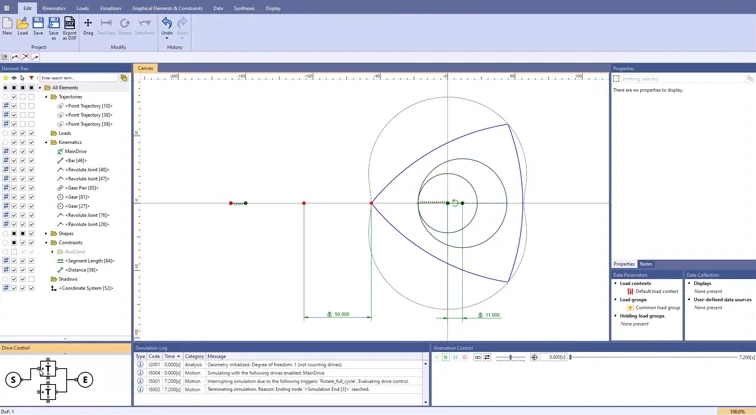
Wankel engine
Constraints fix the gear ratio at 2 : 3. The trajectories of the rotor apexes form the housing contour – even when you change the rotor shape.
The slider-crank of a two-stroke engine at 6,000 revolutions per minute: ASOMv10 calculates the joint and bearing forces, taking the inertia of the moving parts into account.
 1:32
Crank, connecting rod and piston form a slider-crank, with a counterweight on the crank. The forces in the joints and bearings are to be determined. At high speeds or generally high accelerations, inertia often needs to be part of the calculation, because its effects are no longer negligible.
You see early on how strongly inertia changes the forces in joints and bearings, and you factor it into your concept right away.
Calculating with inertia, you design bearings and pins for the forces in operation. More on force calculation
The diagrams show at which crank position the forces peak. More on diagrams
The animation runs slowed down, while the calculation uses the full speed. This lets you follow even fast motion sequences at your own pace.
3:43
Constraints fix the gear ratio at 2 : 3. The trajectories of the rotor apexes form the housing contour – even when you change the rotor shape.
 1:15
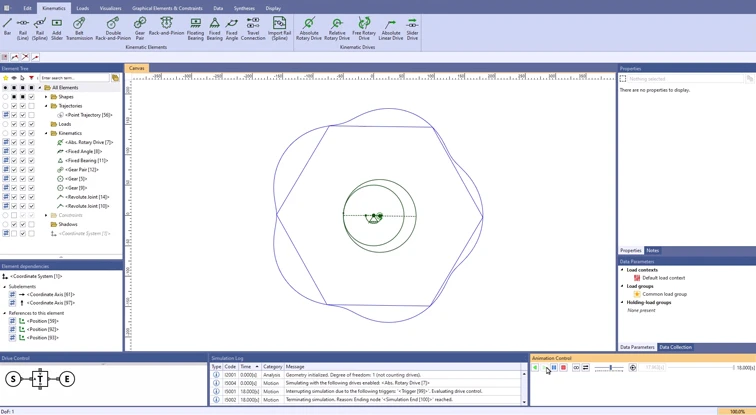
Rotors with three to six apexes compared, each with the matching gear ratio. The trajectories of the rotor apexes form the housing contour.
 3:05
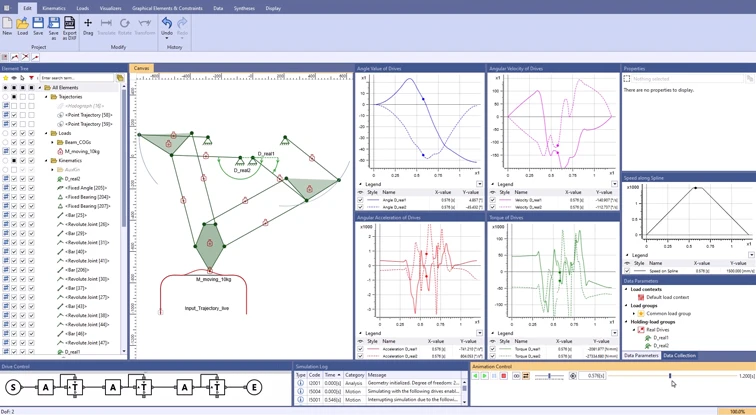
A parallel mechanism with two degrees of freedom: you specify the trajectory, and ASOMv10 provides the angle, speed and torque of the drives, including inertia effects.
Describe your mechanism to us. In an online demo, we will show you ASOMv10 using your example.