
 2:29
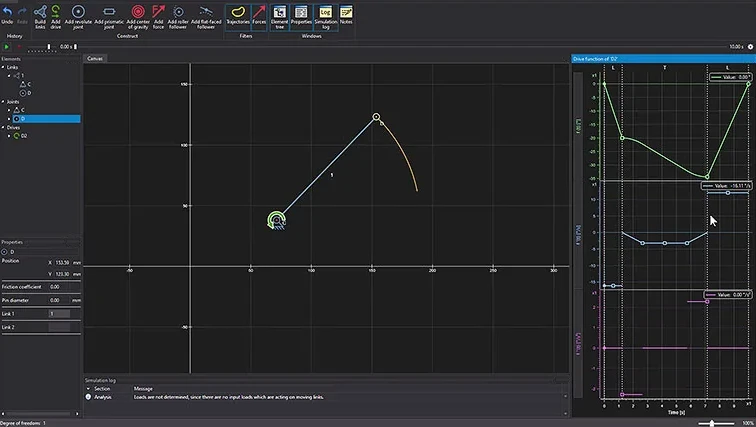
Drive functions
A rotating motion becomes an oscillating motion. You shape the motion profile directly in the diagram, segment by segment.
An excavator arm with three linear drives: the example shows how you coordinate several drives in ASOMmini and track the path of the bucket.
 0:42
The excavator arm is built as a planar mechanism and has three degrees of freedom. Three linear drives move the boom, stick and bucket – one per degree of freedom. For the bucket to move as realistically as possible, the three movements have to be coordinated with one another.
You immediately see how a change to one drive alters the entire motion sequence – already at the conceptual design stage.
You see early on whether the three drives together produce the desired bucket path. More on modeling and motion
You shape motion profiles in the diagram instead of in program code.
Optionally, ASOMmini shows the joint and bearing forces, as vectors on the model and as a diagram. More on force calculation
2:29
A rotating motion becomes an oscillating motion. You shape the motion profile directly in the diagram, segment by segment.
 3:03
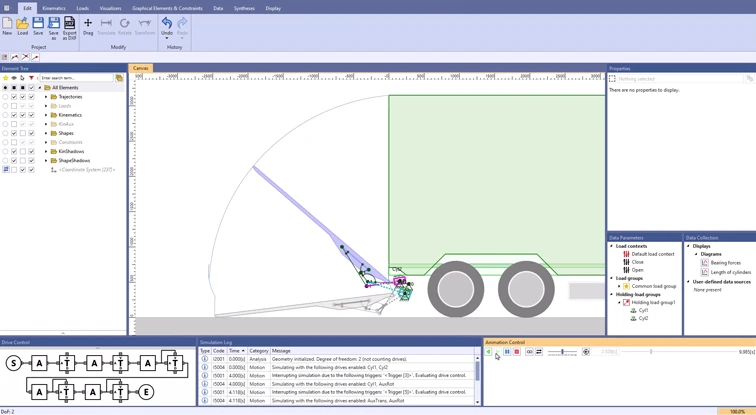
Two hydraulic cylinders open the gate and raise and lower the platform. ASOM combines the partial movements into one motion sequence and calculates the bearing forces with friction.
 3:35
From a blank sheet to a fully rotating four-bar linkage with bearing forces and friction – the whole process in ASOMmini.
Describe your mechanism to us. In an online demo, we will show you ASOMmini using your example.